RIMWORLD环世界
02 / RIMWORLDAETHERLOOP · 穹环

Aetherloop. Built around the tower.

Aetherloop combines a ring-shaped carrier, lifting support and task robots for exterior inspection, water spraying, painting and rust removal. Start with the overall structure, then examine the ring mechanism and individual tasks.

SYSTEM ARCHITECTURE

One structure. Two directions of movement.

The ring surrounds the tapered tower. Ropes from the tower top connect to the inner ring and control vertical travel. Circumferential movement brings the working positions to different sides of the tower.

AETHERLOOP1.0
AETHERLOOP2.0
RING DESIGN / TEAM CAD

The full ring, then the gear detail.

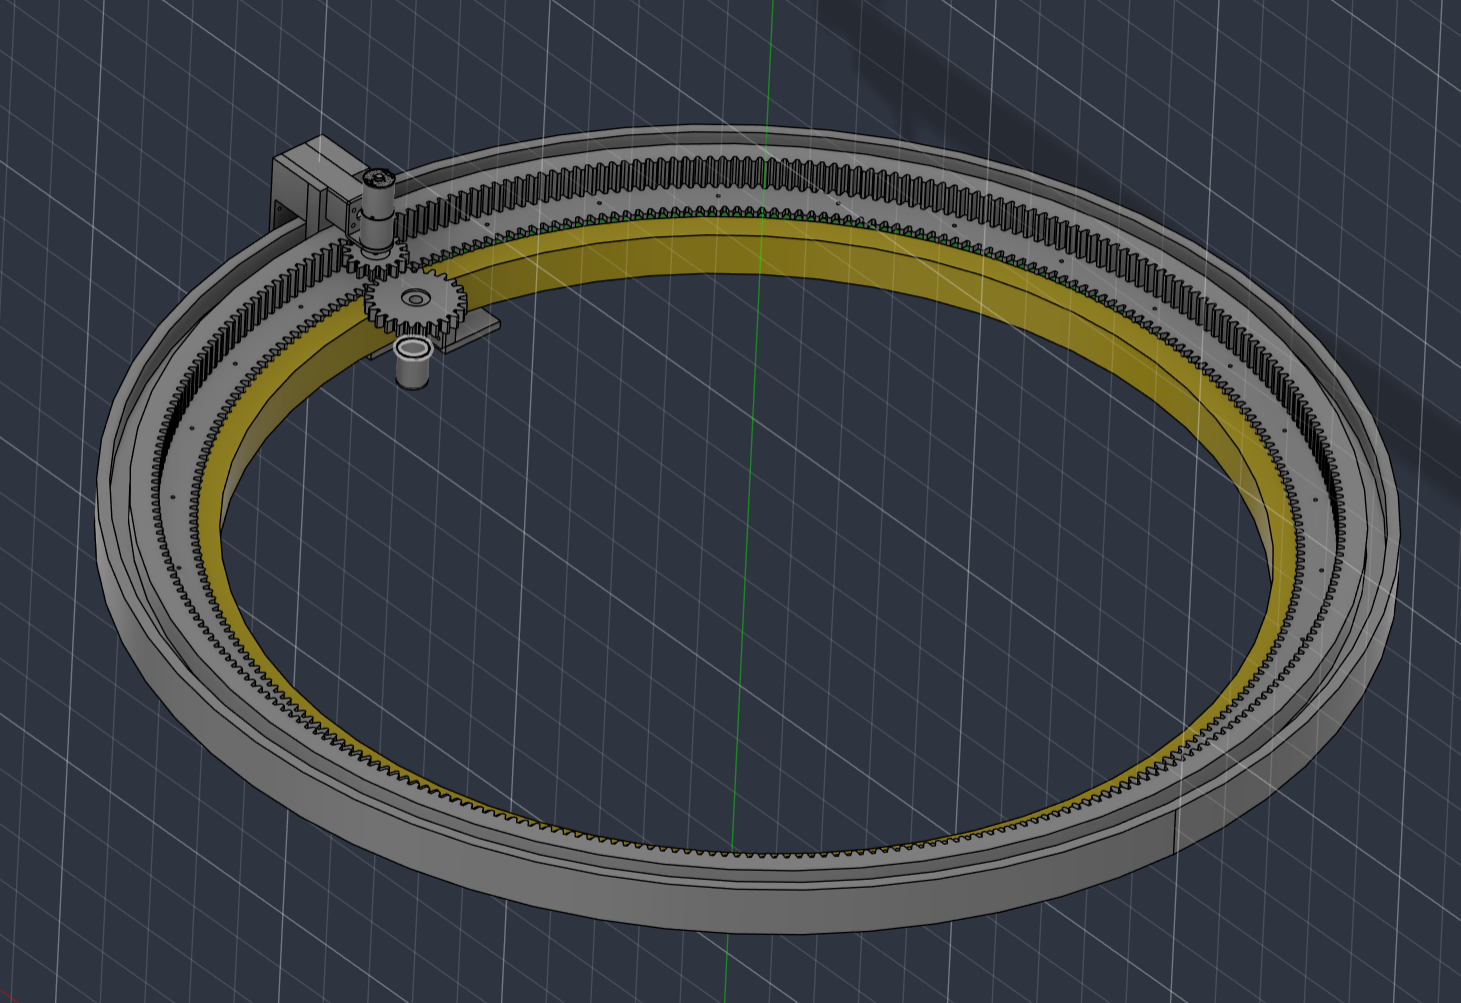
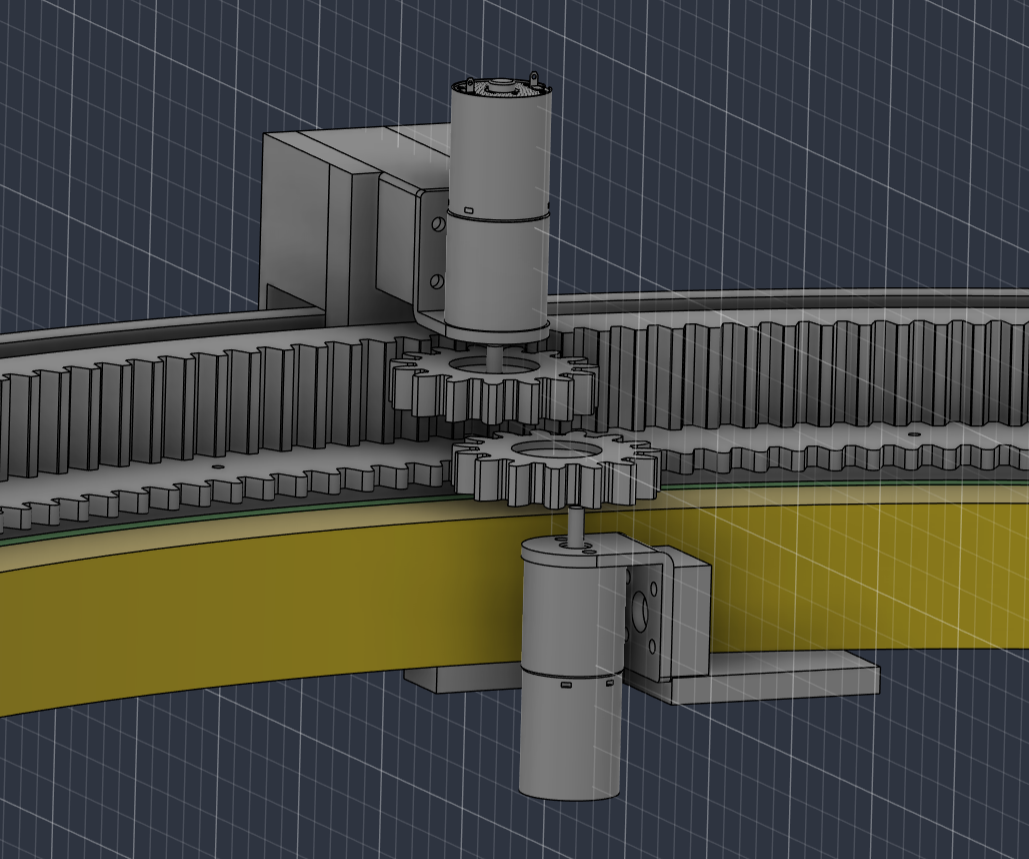
These CAD views show the inner and outer rings, circular gear teeth and local gear assemblies. The overview shows their arrangement around the tower, while the close-up helps examine gear meshing and mounting space.

Team CAD model showing the complete inner and outer rings and gear assemblies
01 / COMPLETE RING

Inner and outer rings

The carrier is more than a circular rod. The model has space between the inner and outer rings, with gear teeth arranged around the circumference and local gears meshing with them. The tower occupies the central opening, with robot working positions arranged around the carrier.

Close-up of gear teeth, two local gears and their mounting components in the team CAD model
02 / GEAR CLOSE-UP

Gear meshing and task robots

The close-up shows the upper and lower gear assemblies. The lower gears connect to a motor at a fixed mounting position to drive ring rotation. The task robots engage with the upper gears and can move freely along the gear ring.

02 / THE SYSTEMTHREE ROBOTS. DISTINCT TASKS.
01
IDENTIFY SURFACE RUST

Surface inspection and rust detection

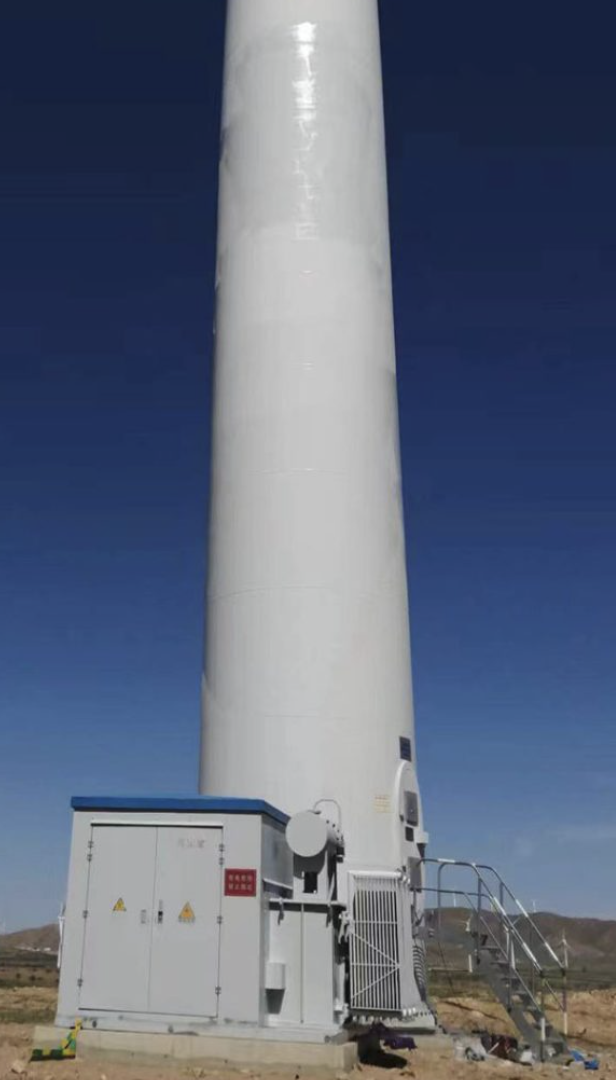
The inspection robot examines the tower exterior for visible rust and areas needing attention. Its findings identify the locations for the other task modules to treat.

Surface inspection / rust detection
02
PREPARE THE SURFACE

Sanding and rust removal

The sanding robot brings its tool into contact with the tower to remove local corrosion. It prepares the surface for subsequent cleaning and coating repair.

Sanding / rust removal
03
CLEAN & COAT

Water cleaning and painting

The spraying robot performs water cleaning and paint application. Water cleans the working area, and paint is applied to the prepared surface. The module brings cleaning and coating care to the same working area.

Water spraying / paint spraying
AETHERLOOP / ENGINEERING

From inspection to recheck.

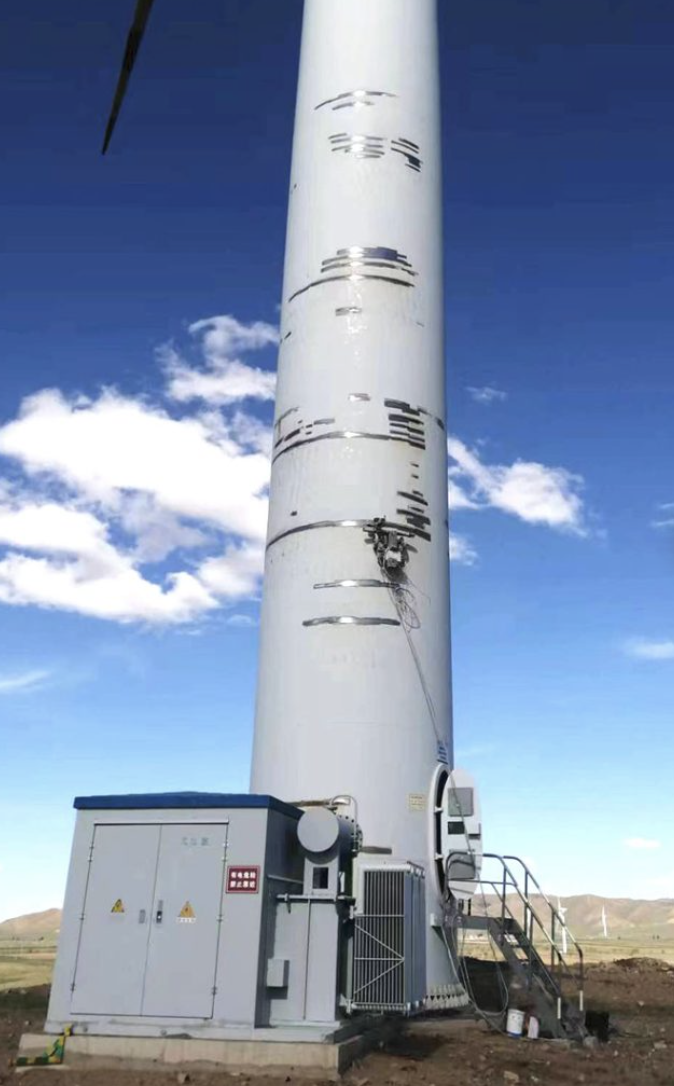
Inspect and record the location first, then select cleaning, rust removal or painting as needed. Areas without rust do not need repeated sanding, and painting follows surface preparation. The proposed sequence is shown below.

  1. 01

    Assess the surface

    Record visible corrosion, coating damage and their locations, then define the area for the job.

  2. 02

    Prepare the area

    Arrange water cleaning and sanding as needed, then check the edges for untreated patches.

  3. 03

    Restore the coating

    Paint after surface preparation, then check coverage, missed areas and local build-up.

  4. 04

    Review & record

    Record before-and-after images at the same location, noting the work performed and any remaining issues.

SURFACE / BEFORE & AFTERDRAG TO COMPARE

Tower surface: before and after

Surface-treatment visualisation.

TECHNICAL DOCUMENTATIONIN PREPARATION

About Aetherloop

Working principle

Aetherloop uses four suspension ropes to raise and lower the ring assembly. Gear transmission on the inner ring controls rotation of the complete assembly around the tower, while the outer ring serves as a track for the carriages to move independently. Vertical travel, assembly rotation and carriage movement work together to position inspection, sanding and rust-removal, and water- and paint-spraying tools at different locations on the tower surface.

RIMWORLD / AETHERLOOPFollow the development